
SIM IS REAL
We build machine vision
for the physical world.
Physical world.Watch the 29-second assembly film
Built by Bucket Labs, a division of Bucket Robotics. From simulation to machine vision, with commercial inspection deployed on production lines.
From digital instructions
to a real build.
Watch the digital assembly become workbench guidance, with on-screen step checks during a real LEGO F1 build.
Inspect the digital assembly.
One digital assembly, shown part by part and stage by stage, then visualized on a physical hand. Inspect the model and the interfaces we built around it.
Part counting on an iPad.
An iPad camera turns a view of loose bricks into proposed part identities and counts. The recording shows the interface in use; exact counts still need checking.
Interface demonstration. Whole-scene counts were correct in approximately 40–46% of the separate scattered-photo evaluation; its detection score does not apply to this recording.Trained in simulation.
Tested in the real world.
We trained a brick detector on rendered scenes and tested it on photographs of real bricks. The result demonstrates transfer from synthetic training images to real-world detection.
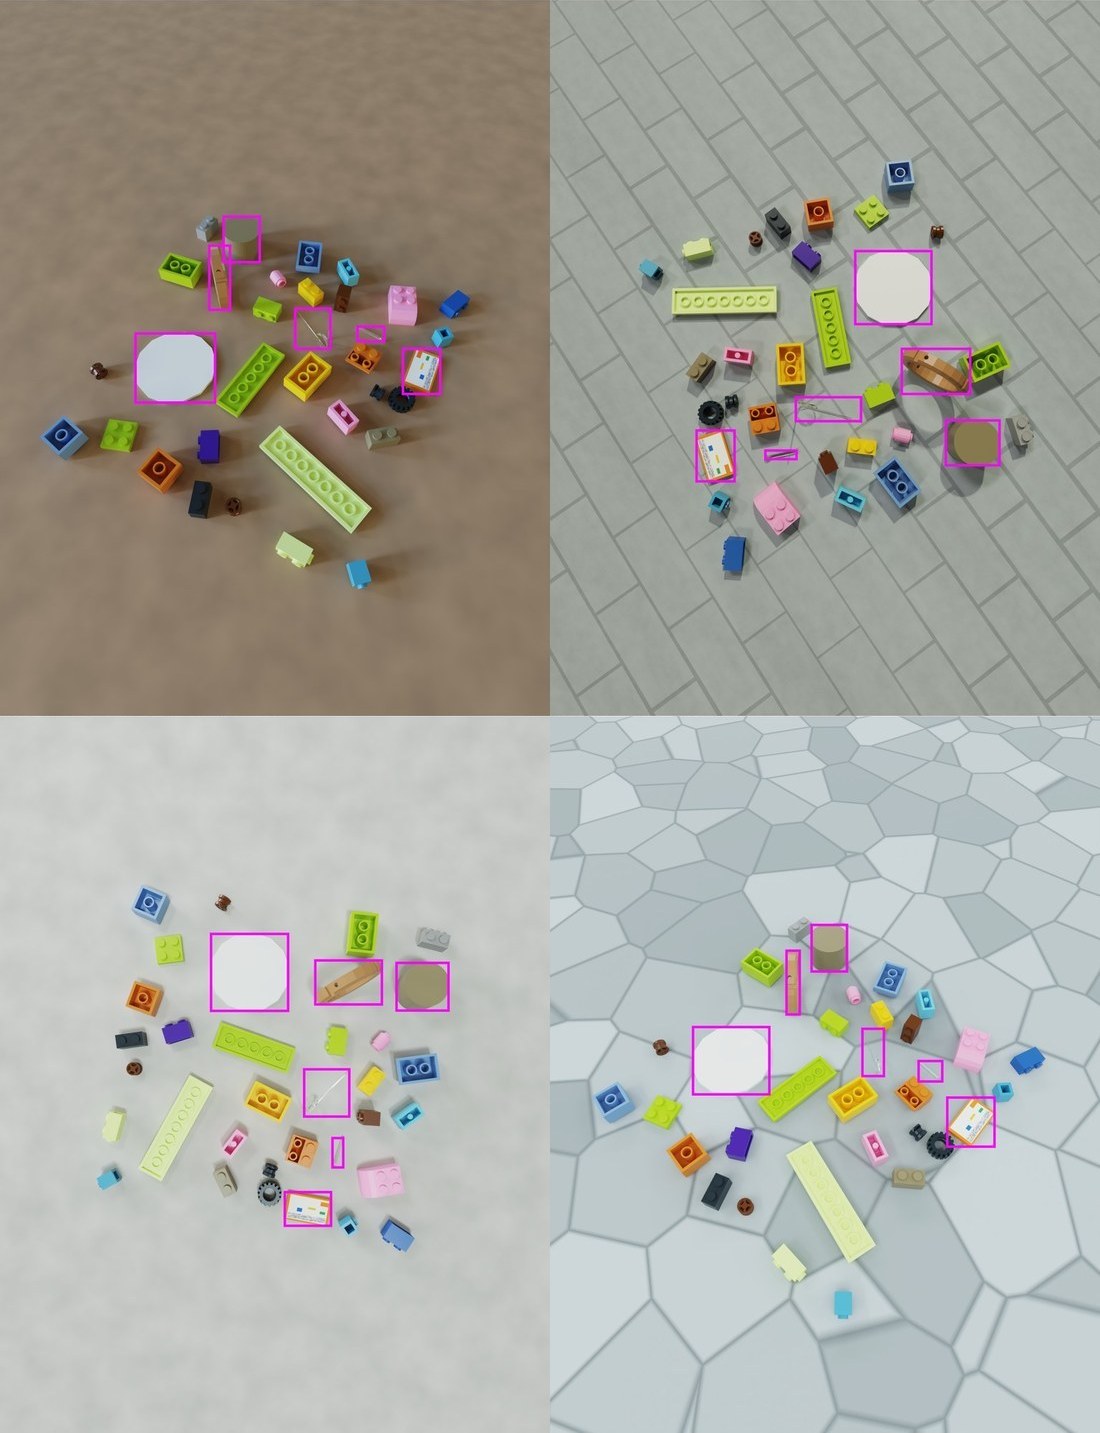
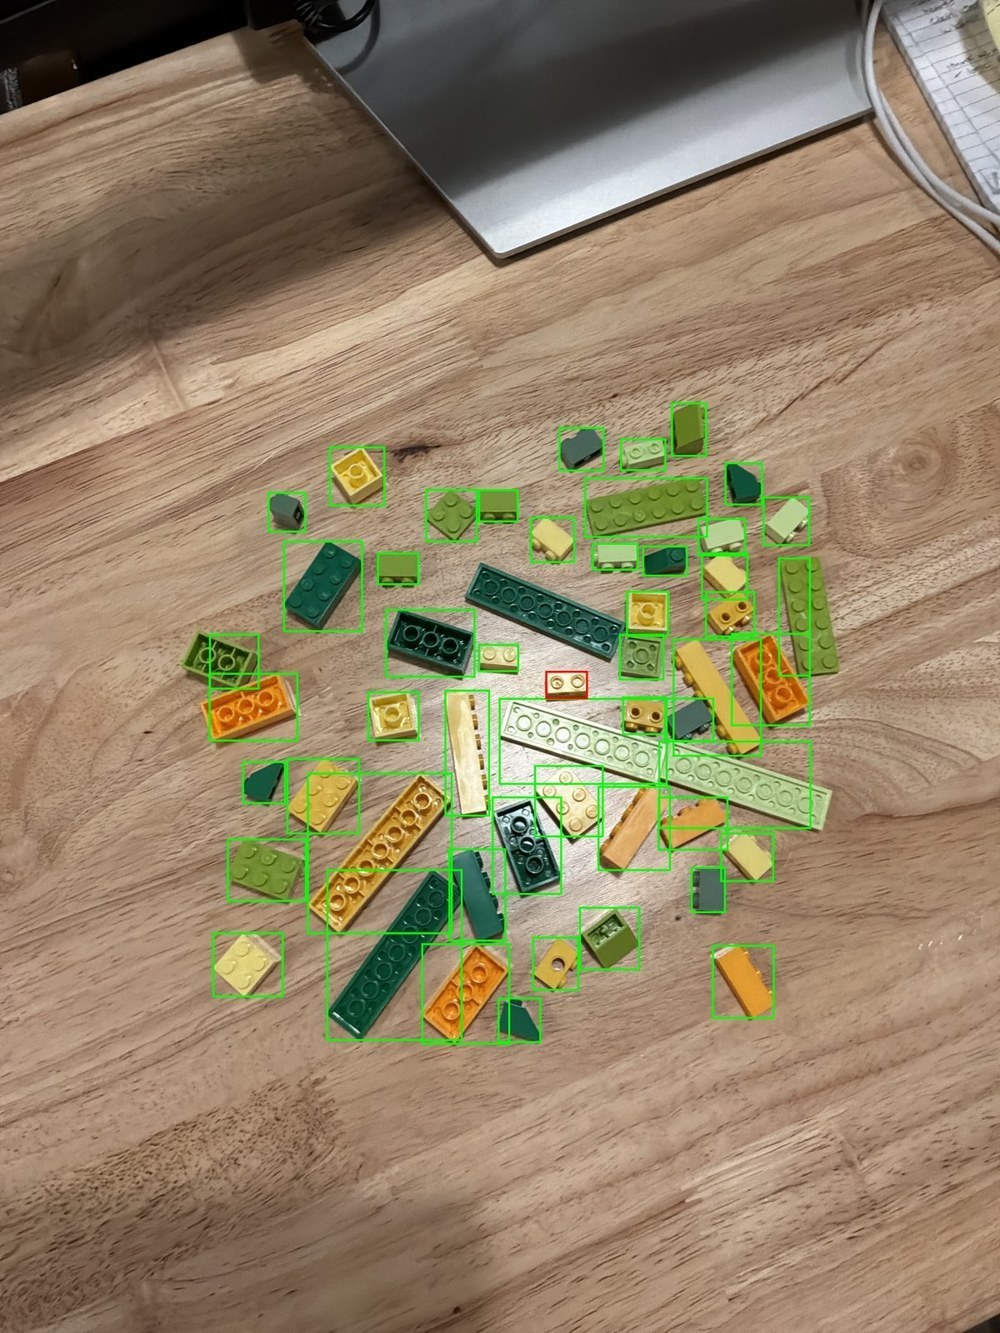
Detection at IoU ≥ 0.5 on scattered bricks. This score does not measure shape-and-colour identification or exact counting.
Detection and exact counting are different tasks. Inspect the evaluation details for counting performance and scope.
We deploy inspection
on production lines.
Bucket Labs is a division of Bucket Robotics. Alongside the demos shown here, Bucket Robotics operates commercial inspection systems for manufacturers—checking parts and assemblies within the workflows of real production lines.
- Cologne, GermanyCable-chain assembly inspectionPart number, link count and orientation checks for a manufacturer.
- San Antonio, TexasInspection at the robot handoffChecking molded parts earlier in the production process.
- South San Francisco, CaliforniaMotor production inspectionExpanded from one inspection station to full production-line coverage.
These are commercial inspection deployments. The LEGO demonstrations above show separate work by Bucket Labs.
The result. The scope.
The recordings.
Review what the detection evaluation measures, where counting falls short, and what each film demonstrates.
Detection evaluation and demo scope
The reported score measures brick detection in real photographs after training on rendered images. Real photographs also informed development; evaluation was not blind.
Exact counting requires every brick to be accounted for without misses or duplicates. Whole-scene counts were correct in approximately 40–46% of scattered photographs, with piles remaining a challenge.